Robot Design Studio - Finger Testbench
An N+1 tendon-routing testbench, one of three parallel class builds
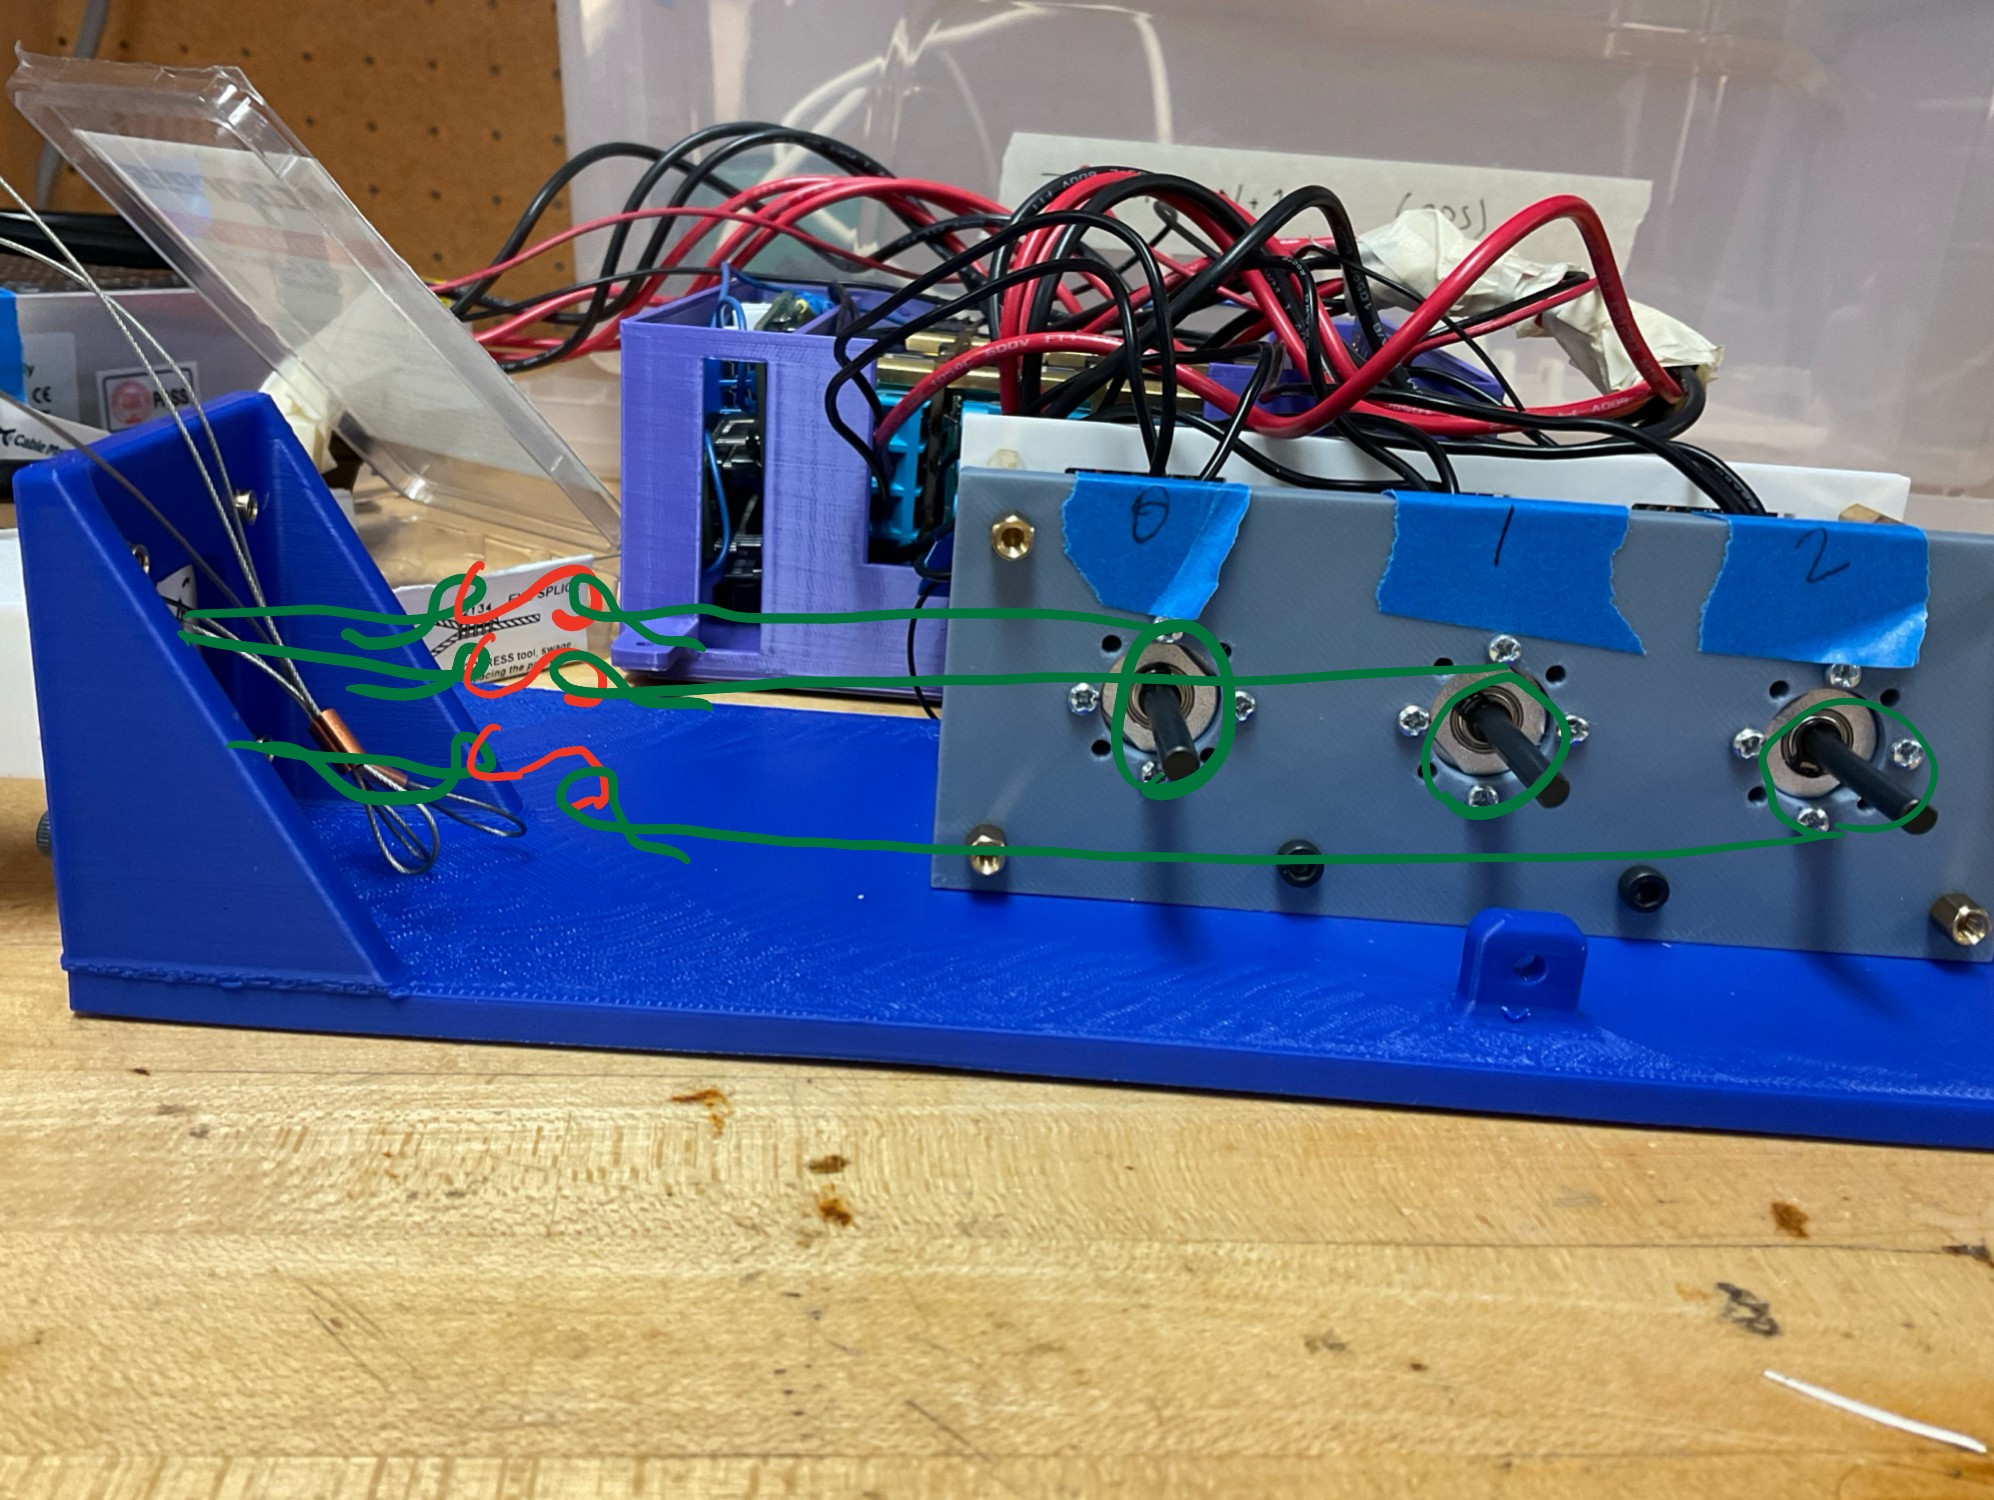
This was a separate class project, completed before the Capstone hand project (Power Finger included). The class split into three groups, each building a testbench around a different tendon-actuation scheme to see how it behaved in practice. My group’s assignment was an N+1 configuration, three motors driving a shared set of tendons rather than one motor per joint, and I managed the mechanical design for the group.
The photo above is one I marked up during the build to track tendon routing: each of the three motors (labeled 0, 1, and 2) feeds a tendon back through a shared termination and tensioning bracket, with the cable ends swaged rather than tied off. Working through the routing by hand like this, tracing which motor’s tendon went where, was most of the mechanical design problem: an N+1 scheme only works if the routing actually produces the coupled motion it’s supposed to, and that’s much easier to verify by tracing real cable than by reading the CAD.